Work · 10 projects
Projects, from raw data to working systems
Each case study covers the problem, my contribution, the architecture, how it was evaluated and where it fails. Filters are shareable: the URL keeps them.
Project list
01Computer Vision · Edge Deployment
I built a detector and tracker for 3–7 pixel aerial targets in infrared video, then ported it from Python to C++/CUDA/TensorRT: 1.7 ms per frame, 9.3× faster, with tracks identical to the prototype.
1.7 msper 1280×1024 frame, enhance → detect → track
02Robotics · Signal Processing
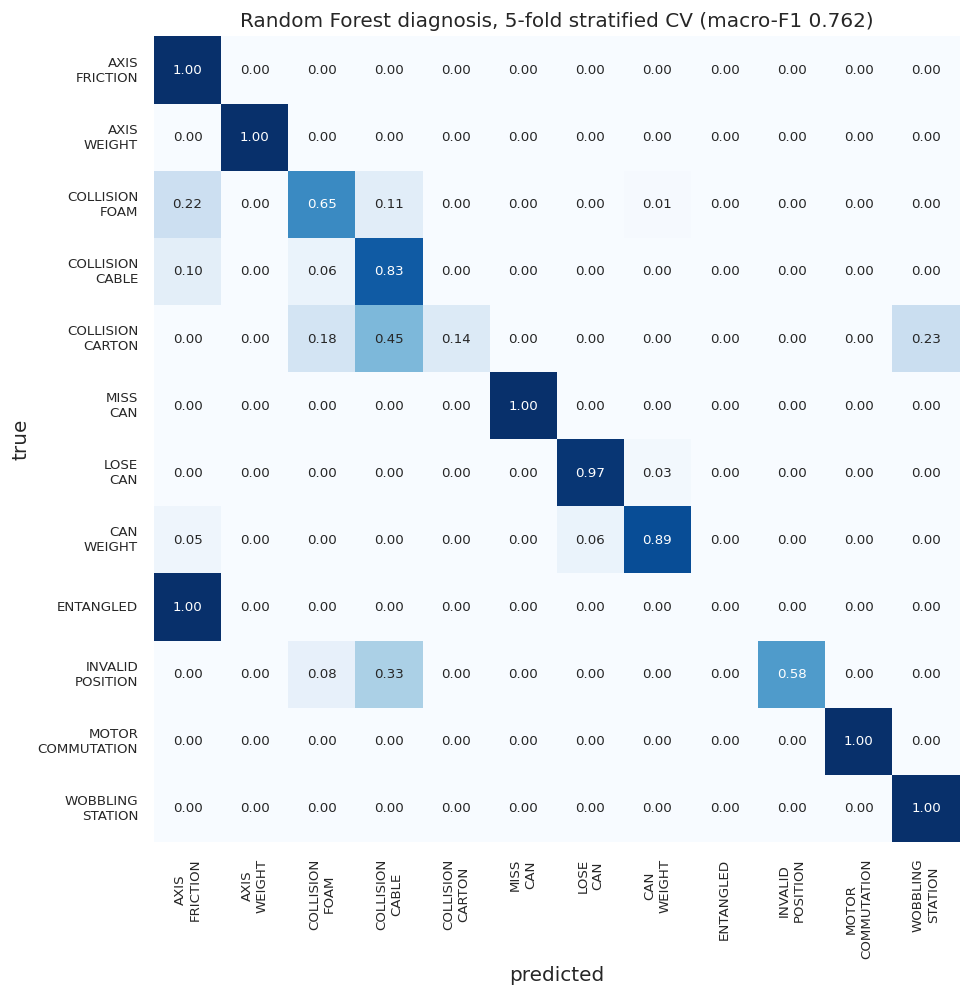
I built an interpretable pipeline on real cobot telemetry: an unsupervised detector flags faulty cycles at AUROC 0.944 with a 1.7% false-alarm rate, and a Random Forest names the fault.
0.944AUROC, faulty vs normal cycles
03Sensor Fusion · Autonomous Systems
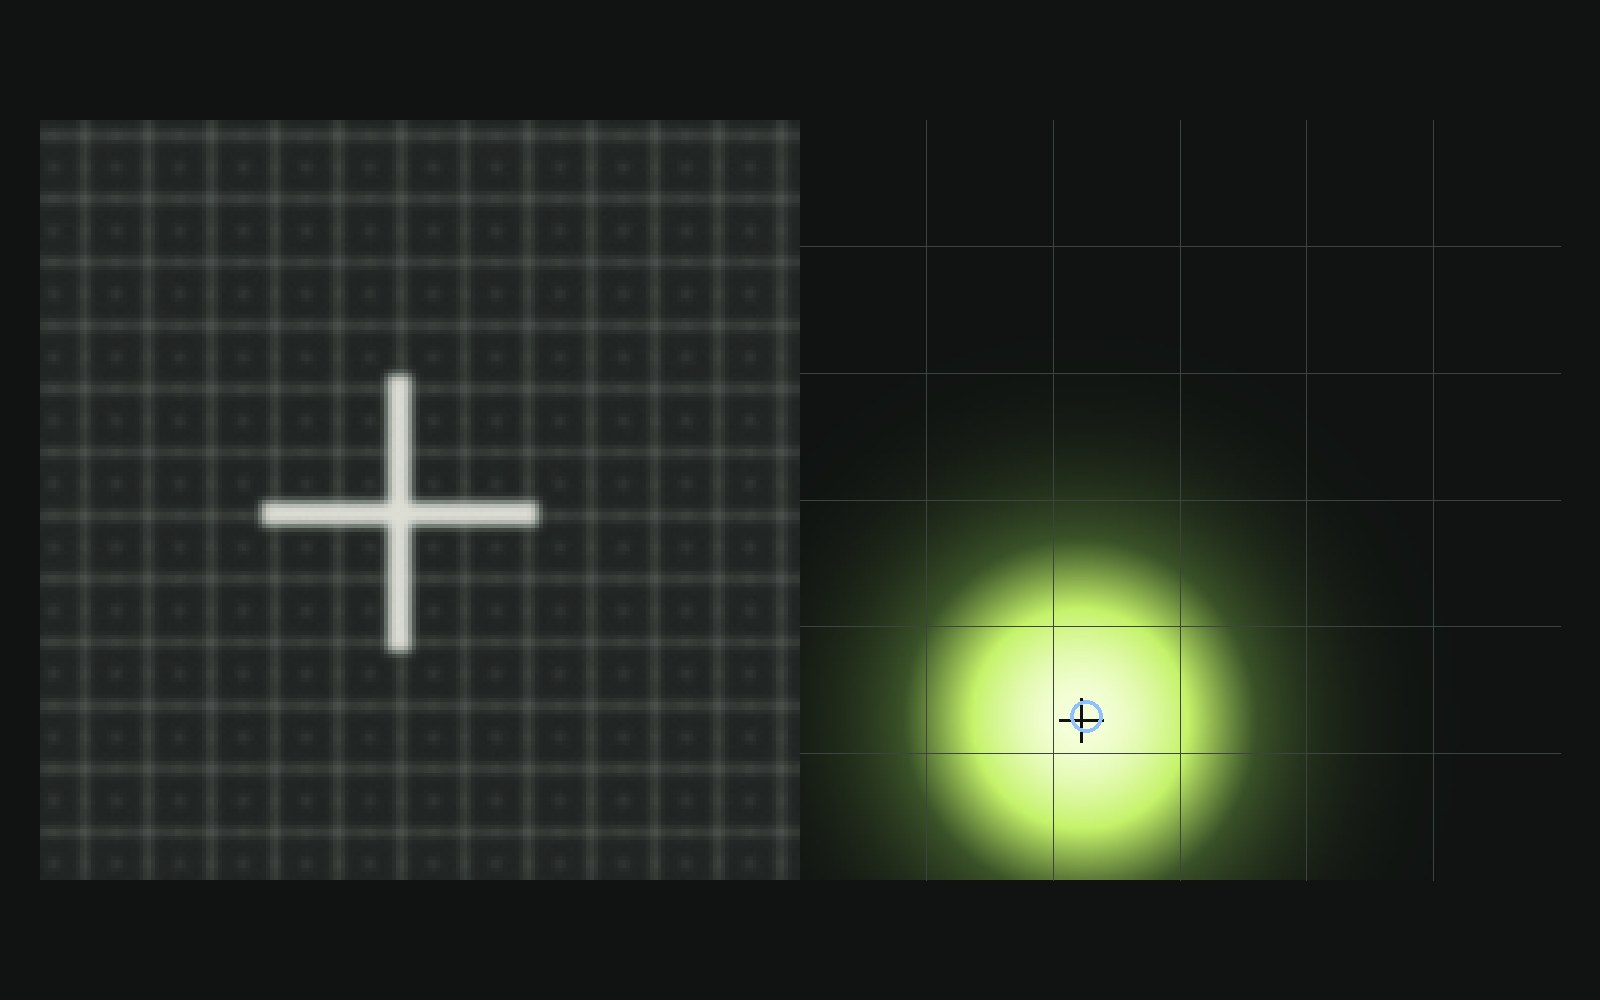
I built LiDAR-to-camera projection for a 120° f-θ lens from raw NVIDIA AV files and gave every segmented object a metric range, over two 605-frame drives.
2 × 605frames fused end to end
04Computer Vision · Deep Learning
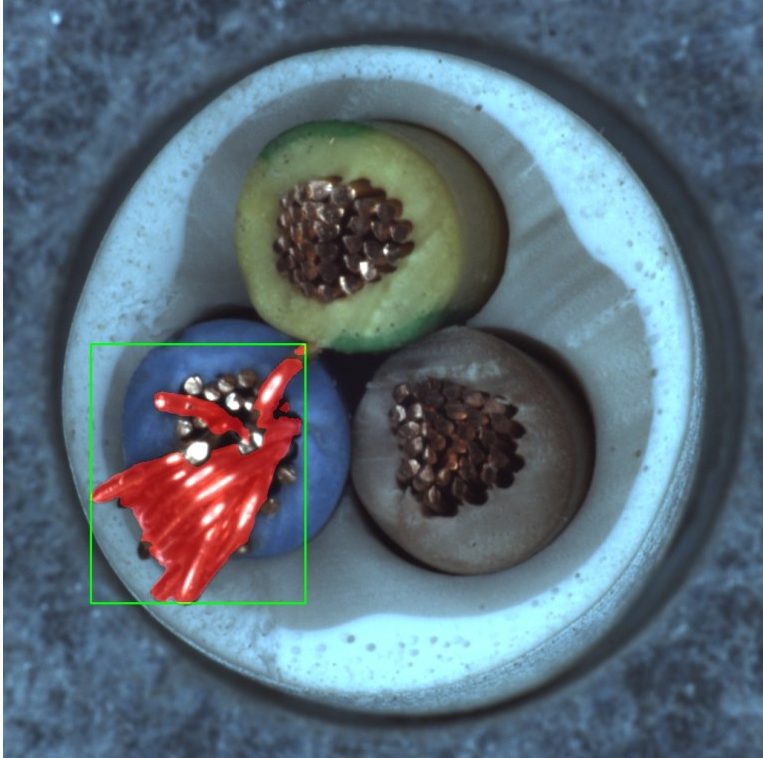
I trained YOLO11-seg on MVTec AD to 0.82 mask mAP50, wrote the C++ TensorRT app that serves it, and found that rebalancing VisA's data lifted mask mAP50 from 0.25 to 0.41 where a bigger model did nothing.
11 / 15held-out defects located by the C++ app
05Signal Processing · Computer Vision
I implemented phase correlation with matrix-multiply DFT upsampling in NumPy: 1/100-pixel shifts that match scikit-image exactly on 50 of 50 tests, benchmarked across four wafer patterns and 15–40 dB of noise.
0.015 pxmean error on a DRAM array
06Computer Vision · Edge Deployment
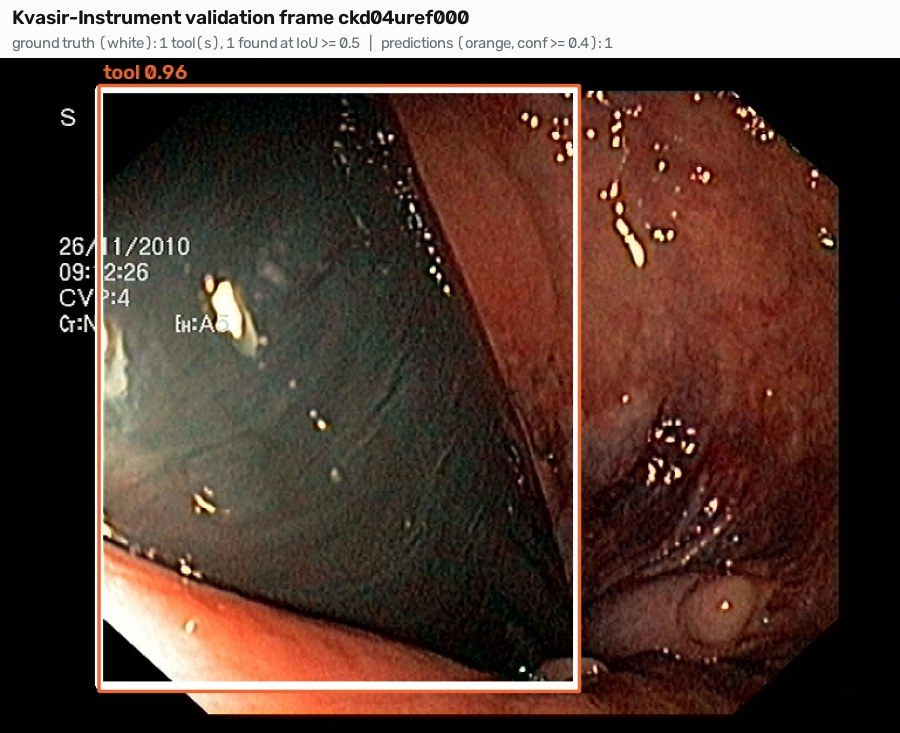
I validated a surgical-tool detector at 0.963 mAP50 over 5 folds, deployed it as a 0.87 ms TensorRT engine behind a Qt panel and a C++ serial relay, and measured an honest cross-dataset drop to 0.17.
0.963mAP50 across 5 folds
07Computer Vision · Autonomous Systems
I wrote a SORT tracker from scratch, ran it against BoT-SORT with camera-motion compensation on all 17 VisDrone test sequences, and caught an ID-leak bug through the output analysis.
08Deep Learning · Autonomous Systems
I fine-tuned Qwen2-VL-2B with QLoRA to 100% valid JSON, then showed on held-out clips that its intent decision stayed at the majority baseline, traced why, and measured what a VLM does to a real-time tracker.
100%valid JSON after fine-tuning
09Computer Vision · Deep Learning
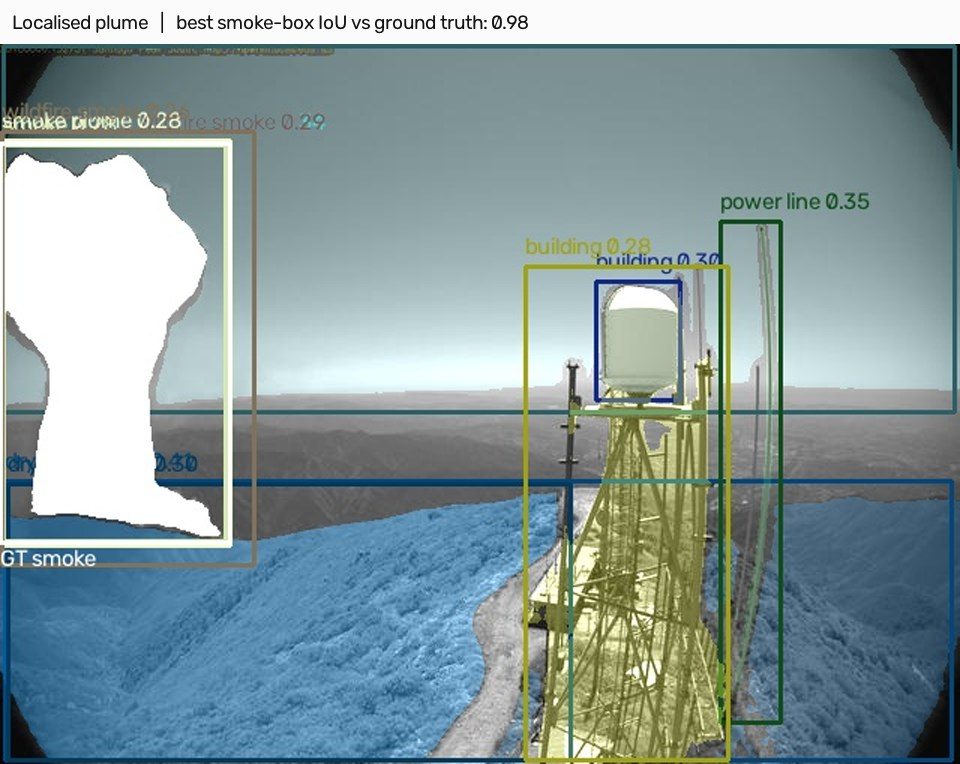
I scored a Grounding DINO + SAM zero-shot pipeline against 744 annotated plumes, raised localisation from 36% to 51% through prompt design, and put the MobileSAM encoder on TensorRT at 4.3 ms.
10Autonomous Systems · Deep Learning
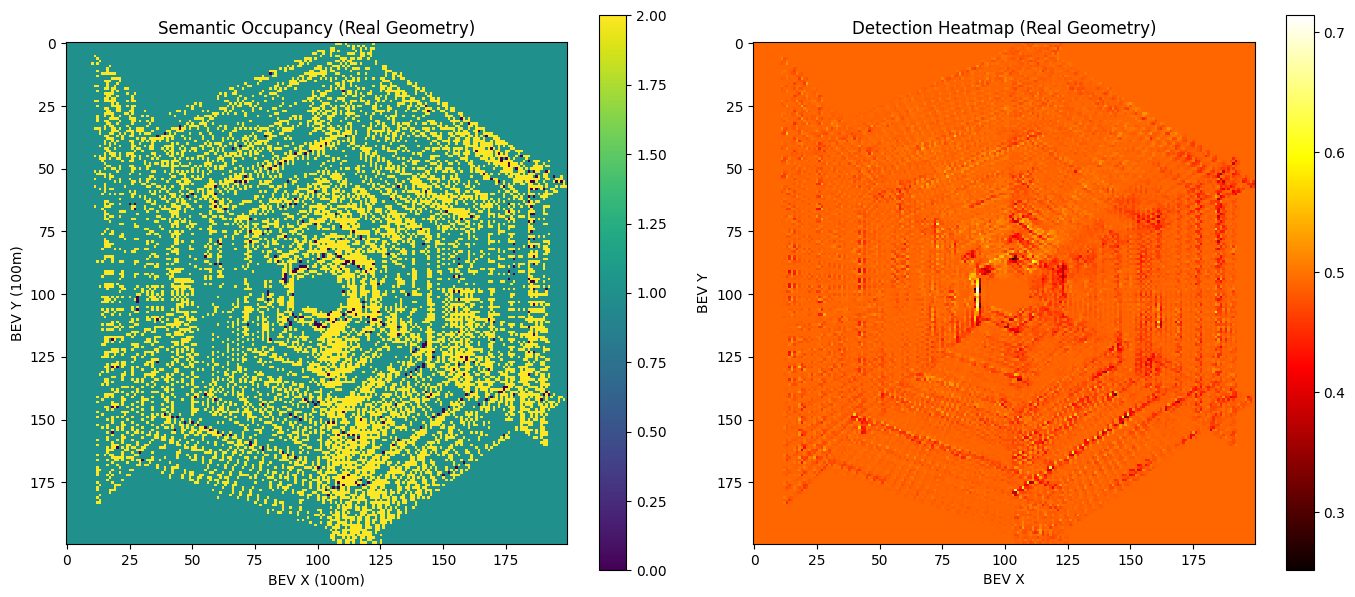
I built a Lift-Splat bird's-eye-view network with a DINOv2 foundation-model backbone, module by module, and verified its six-camera geometry end to end on real nuScenes calibration.
6 cameraslifted into one 200×200 bird's-eye-view grid